OSH100RM
Low-profile rounded body · Four-wheel omnidirectional base
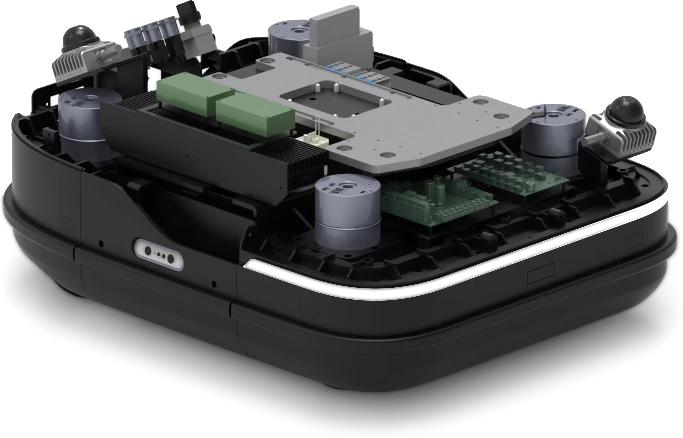
Low-profile rounded body · Four-wheel omnidirectional base
OSH100RM is a general-purpose autonomous mobile robot (AMR) base designed for indoor spaces shared with people, with a rated payload of 100 kg. It features four-wheel omni drive and dual LiDAR 360° autonomous navigation, supports manual charging, automatic dock charging, and suits factories, warehouses and other industrial environments.
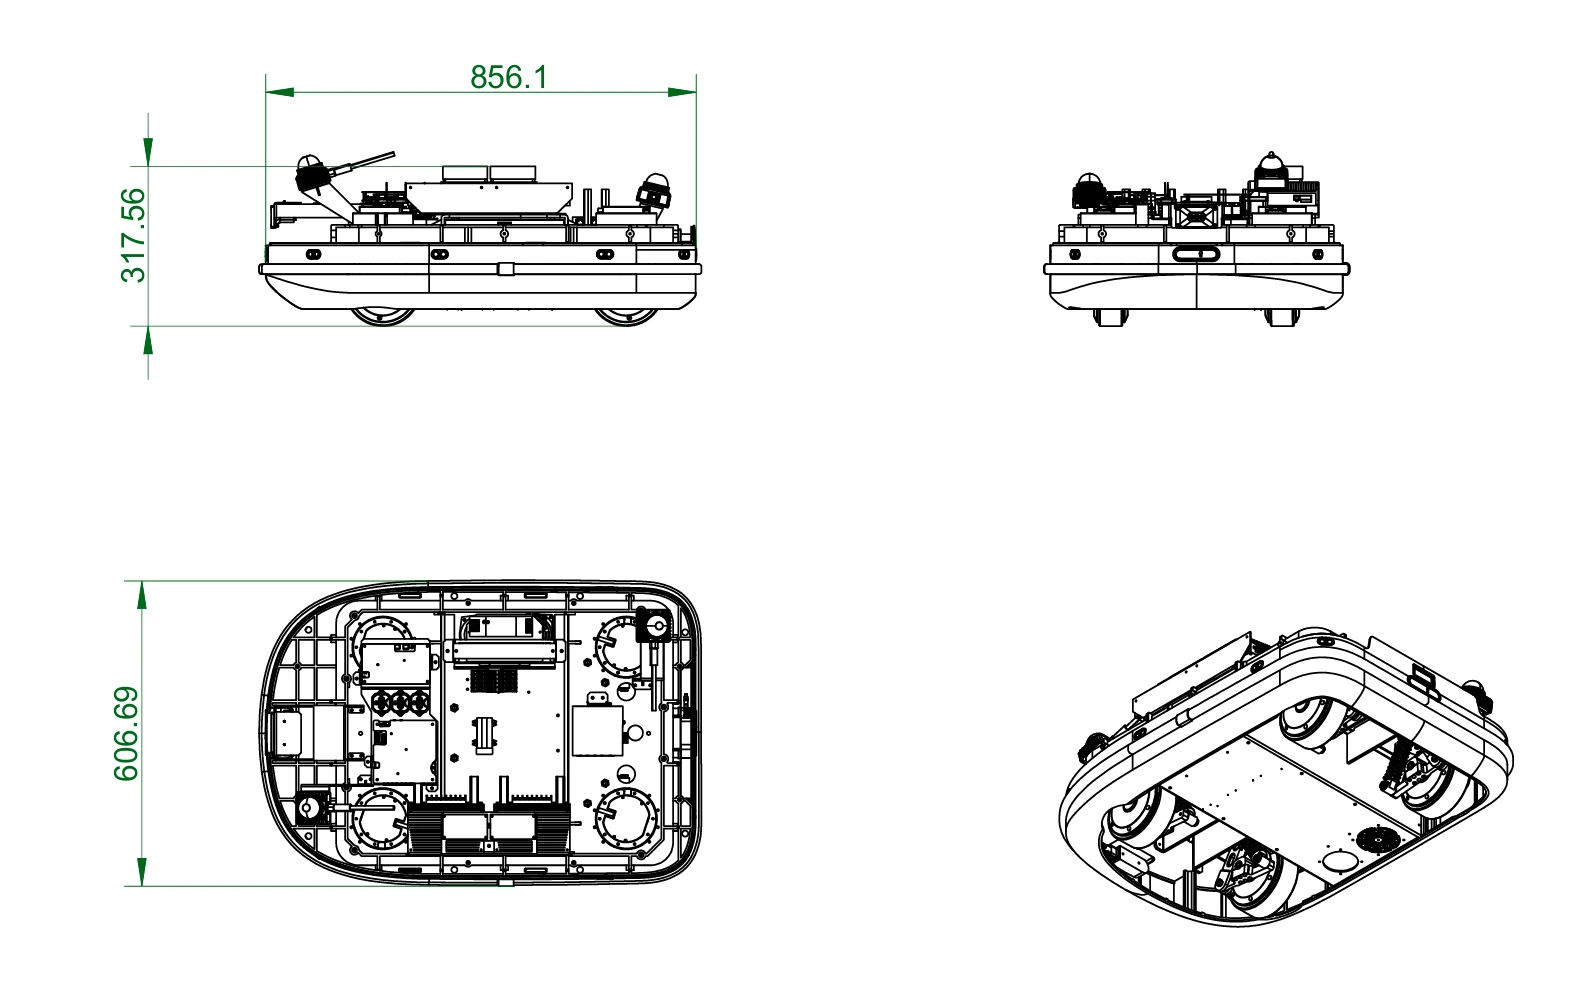
Key highlights
Low-profile rounded body
Only 318 mm tall with a rounded, edge-protected body and an open top deck for upper modules.
Dual-LiDAR 360° navigation
Dual-LiDAR 360° autonomous navigation with positioning accuracy up to ±5 mm / ±1° (VL markers).
42 Ah long runtime
A 42 Ah battery runs about 8 hours at full load, with manual and automatic dock charging.
Fully open development ecosystem
Multiple power, serial and Ethernet ports are fully open; secondary development supports ROS1 / ROS2 / API / SDK, with deep ODM custom development support.
OSH Platform Capabilities
All OSH bases share the same navigation, scheduling and open interfaces, so upper structures migrate smoothly.
Configurations built on OSH100RM
Customers don’t need to develop the low-level drive and navigation system from scratch, greatly shortening the robot development cycle.
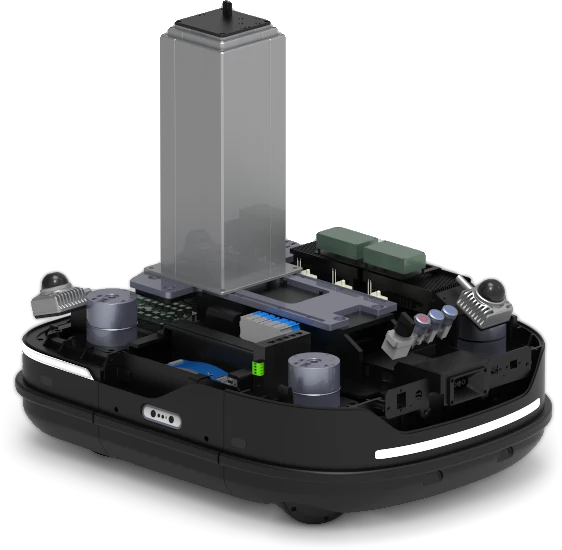
OSH100RM + electric columnBase + electric lifting column
An electric lifting column on the top deck adjusts the working height to match workstations and upper modules of different heights.
Ask about this model →An open foundation from prototype R&D to mass production
More models on site
OSH100RM Technical specifications
Get the full spec sheet PDF →Mechanical specificationsMECHANICAL
Motion performanceMOTION
Navigation & localizationNAVIGATION
Electrical specificationsELECTRICAL
Communication interfacesCOMMUNICATION
Environmental requirementsENVIRONMENT
* Specifications are taken from the Woosh Innovation brochure; the actual product prevails.
Same series · Omni Series
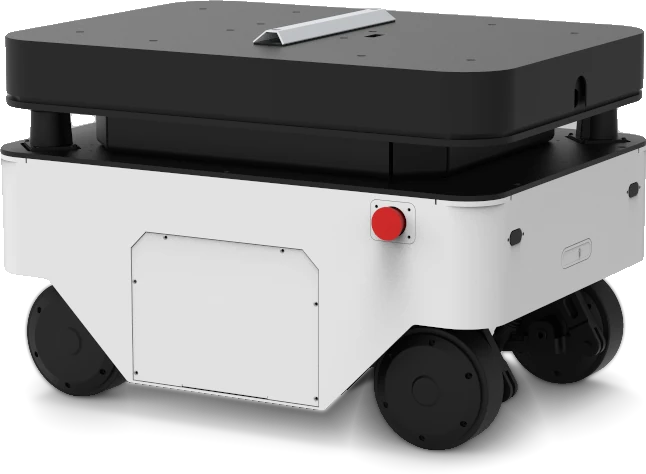
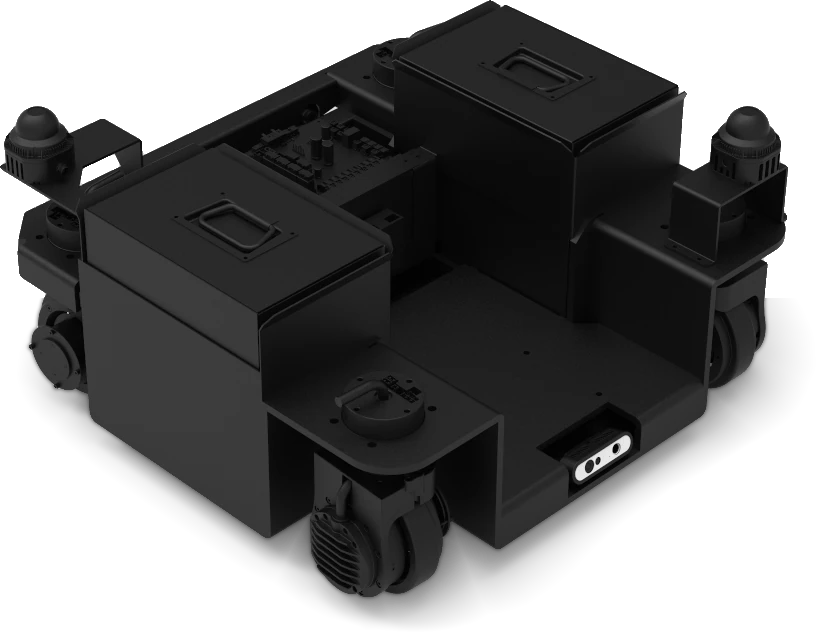
OSH100-OMNI-S
Modular four-wheel omnidirectional base
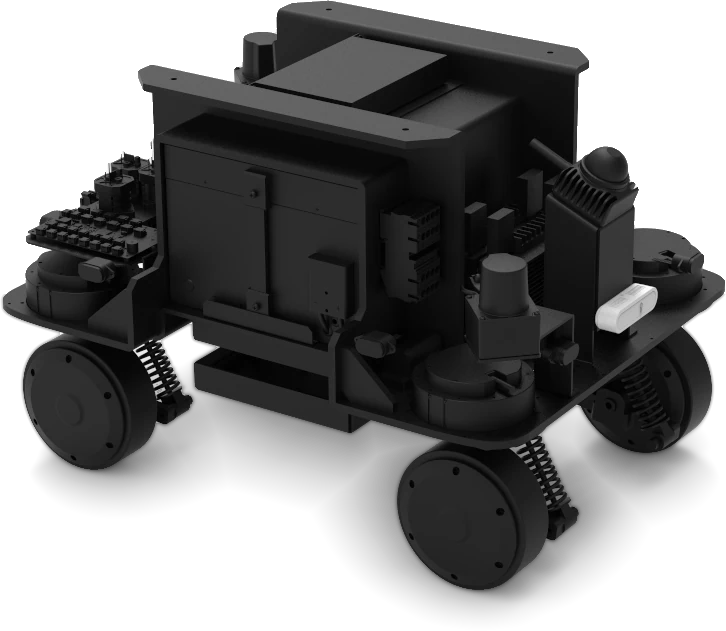
OSH100-OMNI-DV
Dual hot-swap battery omni open base
OSH100-OMNI-DH
Dual hot-swap battery omni open base
Need a custom robot built on OSH100RM?
A solutions engineer will contact you within 1 business day with model recommendations and a quote.