OSH100-MEC-DV
Mecanum four-wheel omnidirectional base · Dual battery packs
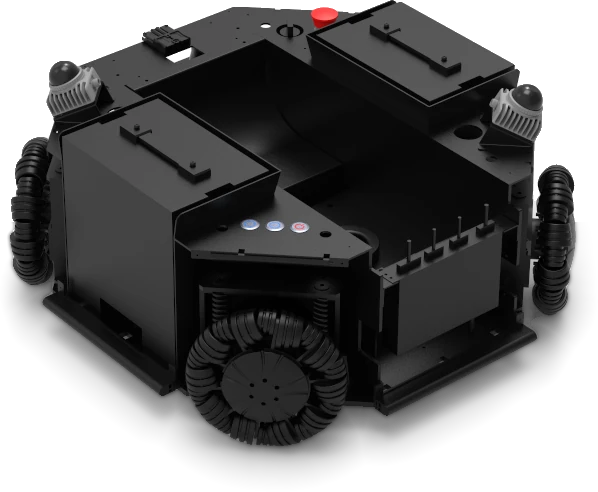
Mecanum four-wheel omnidirectional base · Dual battery packs
OSH100-MEC-DV is a general-purpose autonomous mobile robot (AMR) base designed for indoor spaces shared with people, with a rated payload of 100 kg. It features four-wheel omni drive and dual LiDAR 360° autonomous navigation, supports manual charging, automatic dock charging, and suits factories, warehouses and other industrial environments.
Mecanum omni drive, agile obstacle avoidance
Four-wheel Mecanum omnidirectional drive moves sideways, diagonally and on the spot, weaving around obstacles on its own.
OSH100-MEC-DV real footage
Key highlights
Mecanum omnidirectional movement
Mecanum four-wheel omnidirectional drive moves sideways, diagonally and turns in place for agile dispatch in tight spaces.
Dual-LiDAR 360° navigation
Dual-LiDAR 360° autonomous navigation with ±20 mm / ±3° global positioning accuracy.
Dual battery packs
40 Ah dual battery packs run about 8 hours at full load, with manual and automatic dock charging.
Fully open development ecosystem
Multiple power, serial and Ethernet ports are fully open; secondary development supports ROS1 / ROS2 / API / SDK, with deep ODM custom development support.
OSH Platform Capabilities
All OSH bases share the same navigation, scheduling and open interfaces, so upper structures migrate smoothly.
Configurations built on OSH100-MEC-DV
Customers don’t need to develop the low-level drive and navigation system from scratch, greatly shortening the robot development cycle.
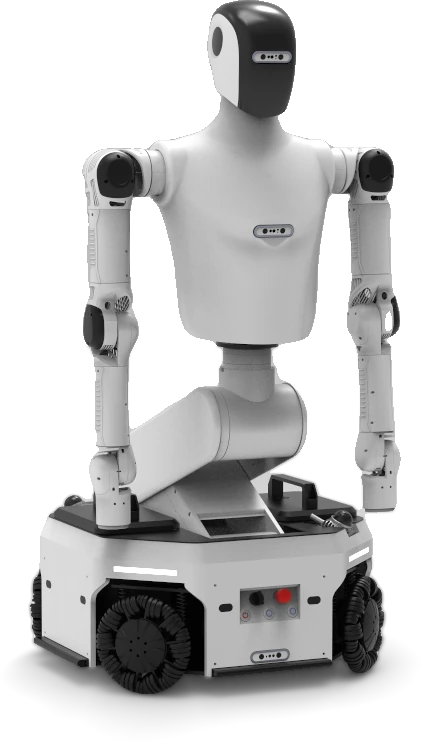
OSH100OW-AE-00Mecanum base (white shell) + dual-arm humanoid upper body
A shelled Mecanum omnidirectional base carries a dual-arm humanoid upper body, forming a wheeled humanoid embodied robot that combines omnidirectional motion with dual-arm manipulation.
Ask about this model →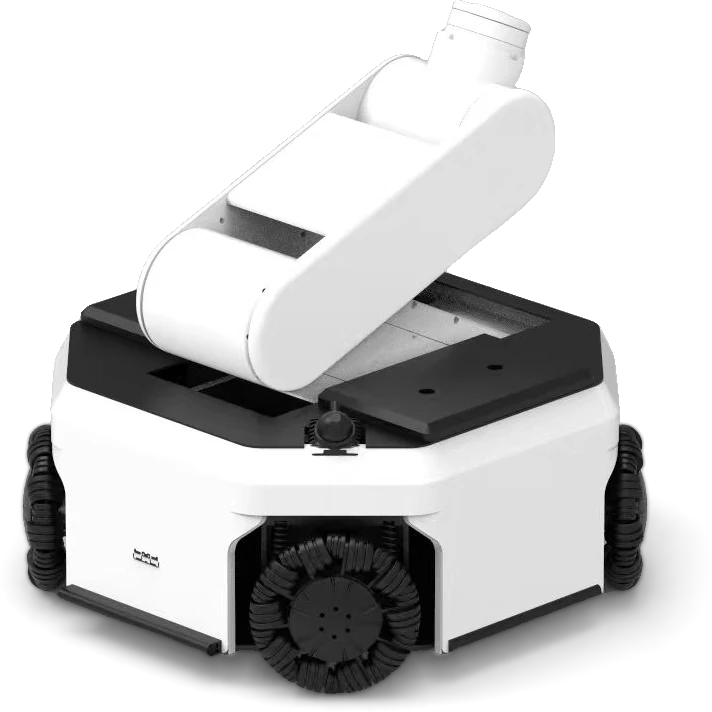
OSH100OW-AE-00 + waist moduleMecanum base (white shell) + waist module
The white-shell Mecanum base carries a waist module whose top flange provides an upper-body mount for a torso, dual arms or other upper structures.
Ask about this model →An open foundation from prototype R&D to mass production
More models on site
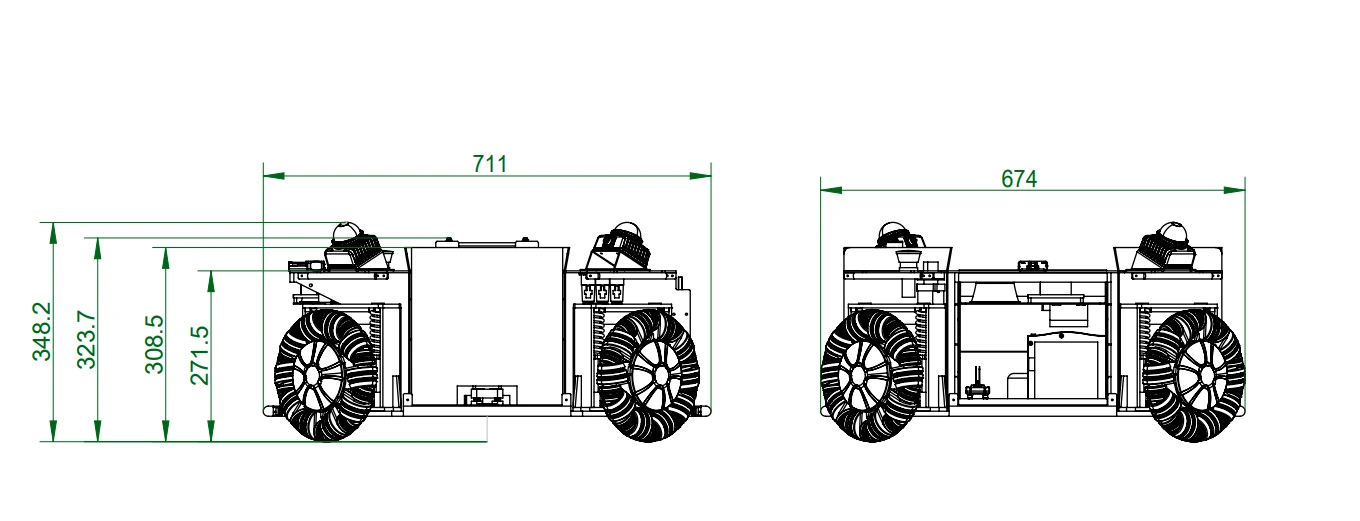
OSH100-MEC-DV Technical specifications
Get the full spec sheet PDF →Mechanical specificationsMECHANICAL
Motion performanceMOTION
Navigation & localizationNAVIGATION
Electrical specificationsELECTRICAL
Communication interfacesCOMMUNICATION
Environmental requirementsENVIRONMENT
* Specifications are taken from the Woosh Innovation brochure; the actual product prevails.
Same series · Mecanum Series
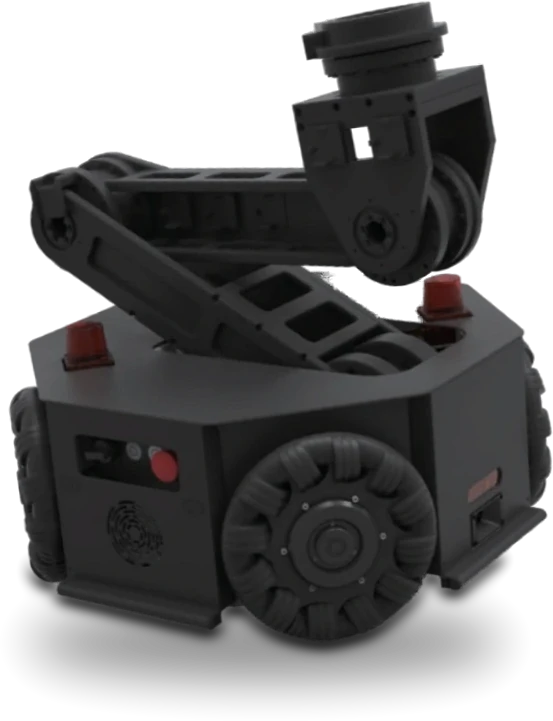
Other recommended bases
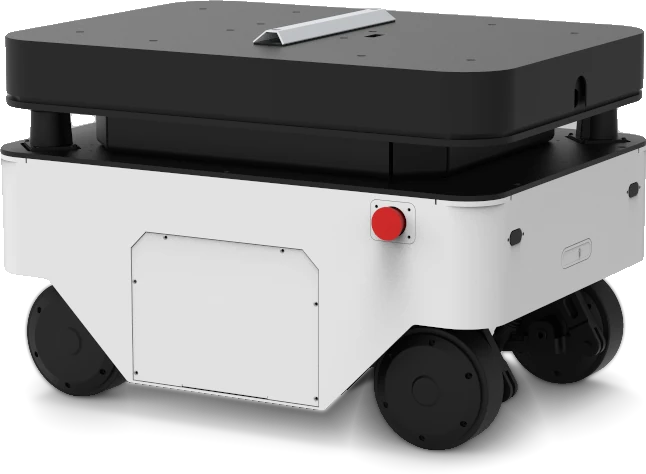
OSH100-OMNI-S
Modular four-wheel omnidirectional base
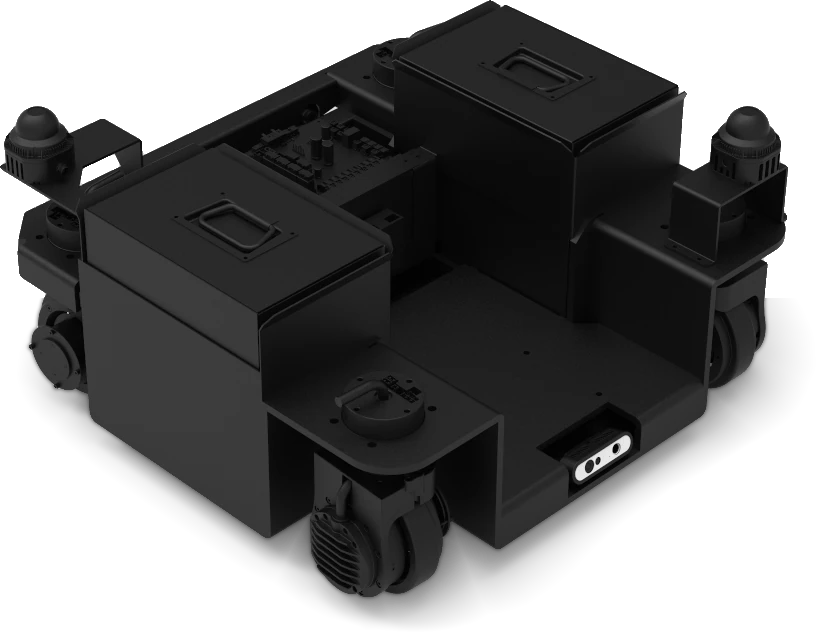
OSH100-OMNI-DV
Dual hot-swap battery omni open base
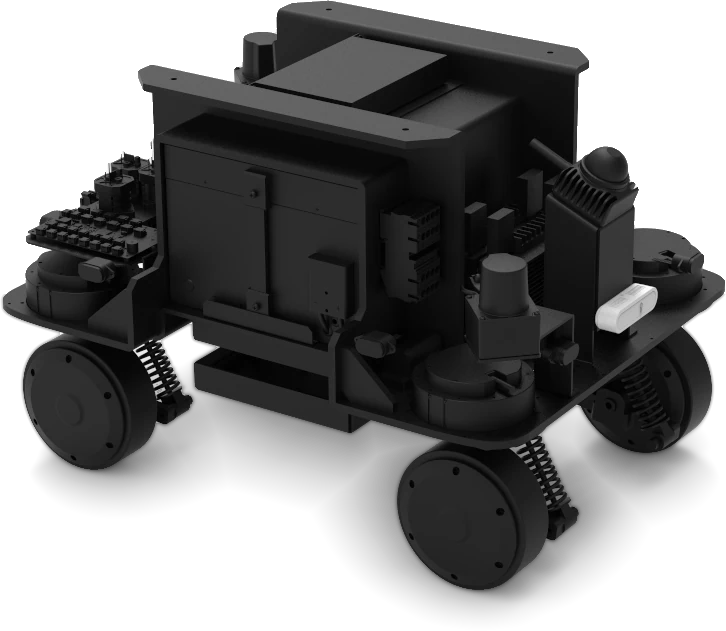
OSH100-OMNI-DH
Dual hot-swap battery omni open base
Need a custom robot built on OSH100-MEC-DV?
A solutions engineer will contact you within 1 business day with model recommendations and a quote.