OSH100-DIFF-S Open Frame
Open-frame modular differential mobile base
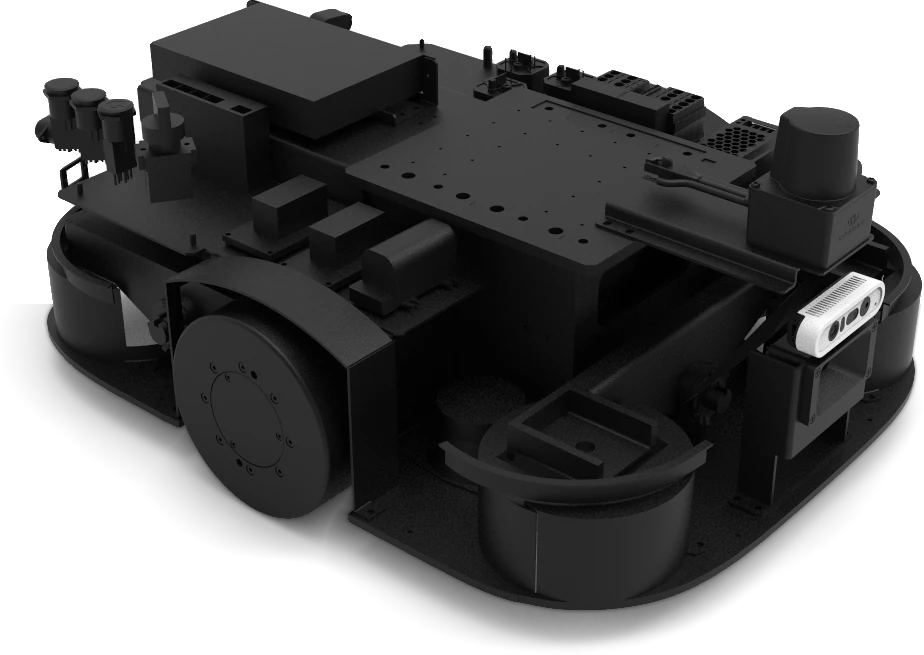
Open-frame modular differential mobile base
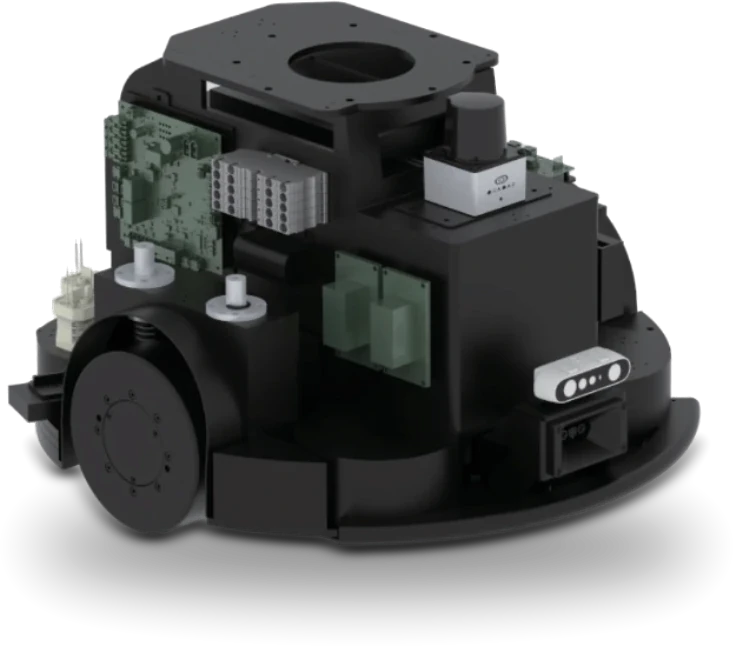
OSH100-DIFF-S (Open Frame) is an open, enclosure-free two-wheel differential AMR base from Woosh Innovation. Customers can define their own exterior design, making it a high-performance platform for R&D integration, custom robots and composite robot development.
The enclosure is removed, fully exposing the drive motors, navigation sensors, electrical interfaces and mounting base. Two-wheel differential drive gives responsive steering, smooth in-place U-turns and excellent narrow-aisle passage, with mature SLAM laser navigation, obstacle avoidance, path planning and auto-recharging preinstalled. Ideal for university labs and R&D teams debugging robot algorithms and testing prototypes.
Key highlights
The OSH100-DIFF-S open-frame base is an open robot development platform covering everything from basic mobility and lifting to intelligent dual-arm manipulation.
Open-frame structure
Enclosure-free open design with clearly visible components, wiring and mounting points, suited to R&D and secondary development.
Highly maneuverable differential travel
Two-wheel differential drive steers flexibly through tight spaces and suits indoor plants, labs and offices.
Exceptional modular compatibility
Four expansion modules — scissor lift, folding bracket, multi-stage electric column and robot arm — are freely optional, leaving plenty of room for customization.
Mature, stable low-level control system
In-house navigation and motion control algorithms with full mapping, obstacle avoidance, route following and auto-recharging, highly reliable over long continuous operation.
Fully open development ecosystem
Multiple power, serial and Ethernet ports are fully open; secondary development supports ROS1 / ROS2 / API / SDK, with deep ODM custom development support.
Highly adaptable to R&D scenarios
Suited to both commercial deployment and research: quickly mass-produce finished robots, or support prototyping and algorithm testing at universities and R&D institutes.
OSH Platform Capabilities
All OSH bases share the same navigation, scheduling and open interfaces, so upper structures migrate smoothly.
Configurations built on OSH100-DIFF-S
Customers don’t need to develop the low-level drive and navigation system from scratch, greatly shortening the robot development cycle.
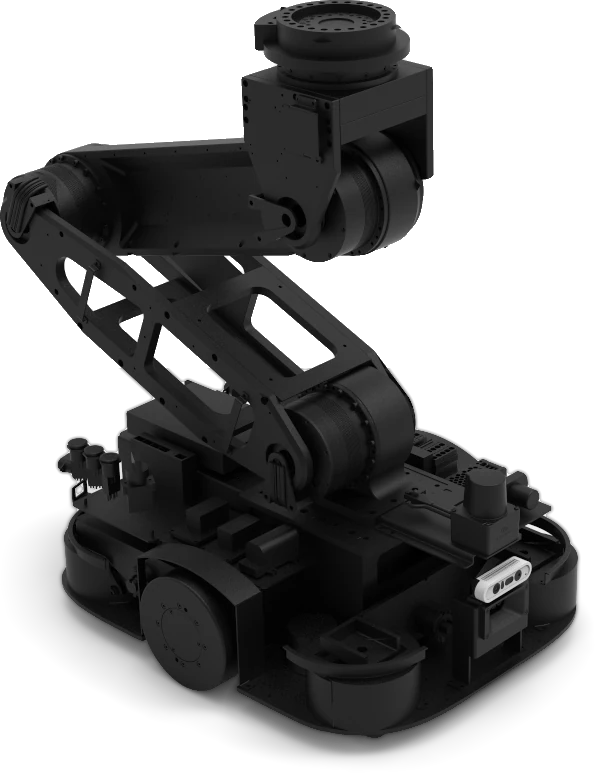
OSH100-SC-DIFF-SBase + scissor lift module
The scissor structure delivers smooth long-stroke lifting with stable load, wide span and strong support rigidity, for quickly building lifting transport and lifting inspection platforms.
Ask about this model →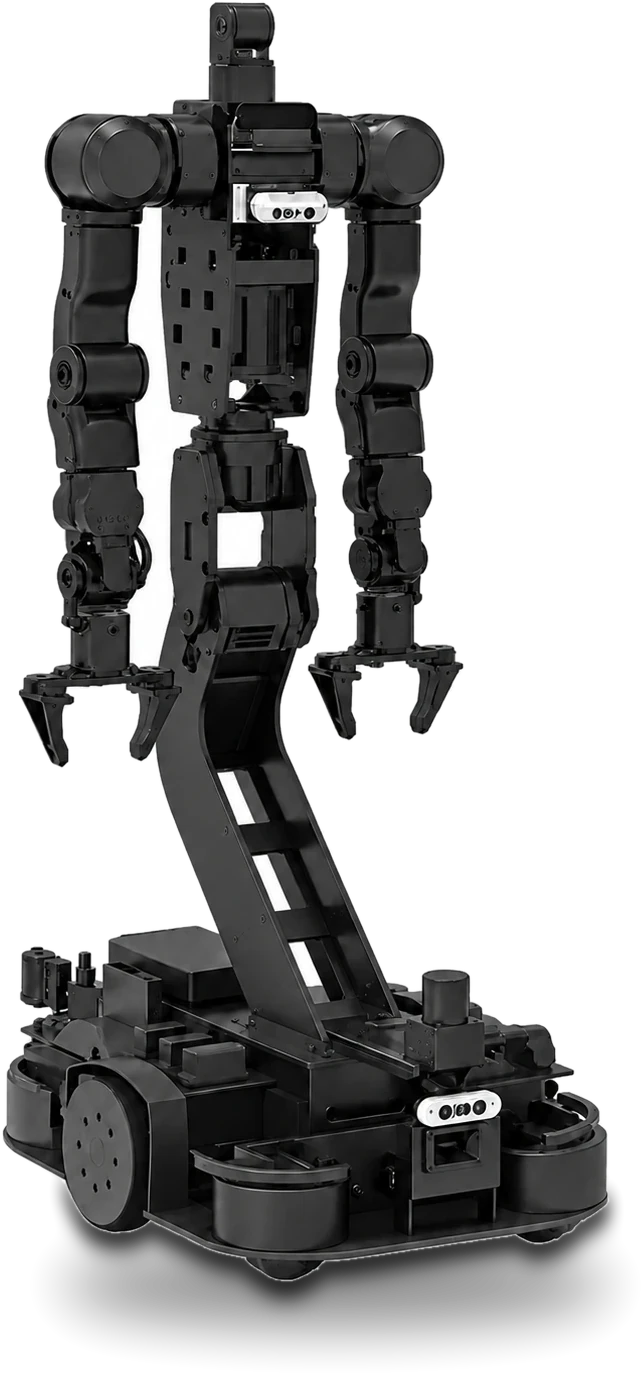
OSH100-FDA-DIFF-SBase + folding bracket + torso + dual arms
Forms the prototype of a lightweight humanoid work robot; dual flexible arms perform fine actions such as grasping, sorting, operating and commissioning.
Ask about this model →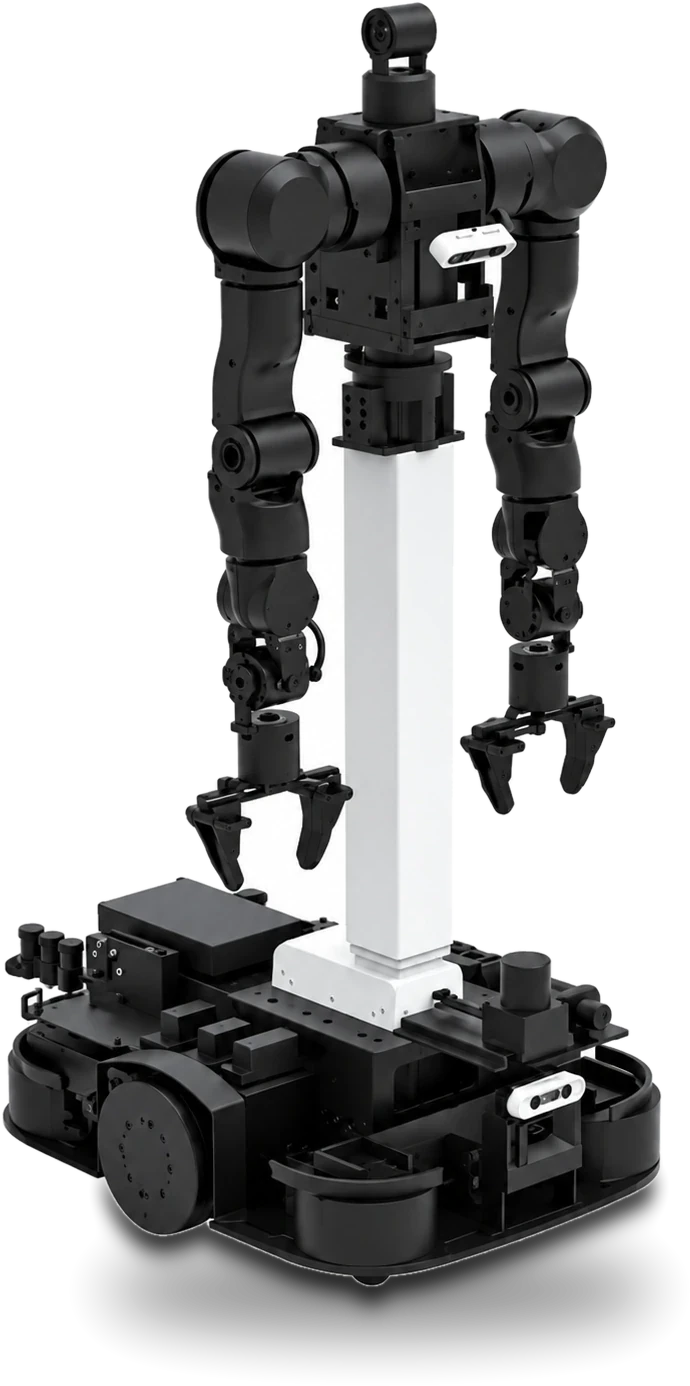
OSH100-LDAE-DIFF-SBase + multi-stage electric lift column + torso + dual arms
Multi-stage electric cylinders lift over a wide range to change the working zone, and dual arms handle precision work — integrators can quickly launch commercial composite robots.
Ask about this model →An open foundation from prototype R&D to mass production
More models on site
OSH100-DIFF-S Open Frame Technical specifications
Get the full spec sheet PDF →Mechanical specificationsMECHANICAL
Motion performanceMOTION
Navigation & localizationNAVIGATION
Electrical specificationsELECTRICAL
Communication interfacesCOMMUNICATION
Environmental requirementsENVIRONMENT
* Specifications are taken from the Woosh Innovation brochure; the actual product prevails.
Same series · Open Frame Series
Other recommended bases
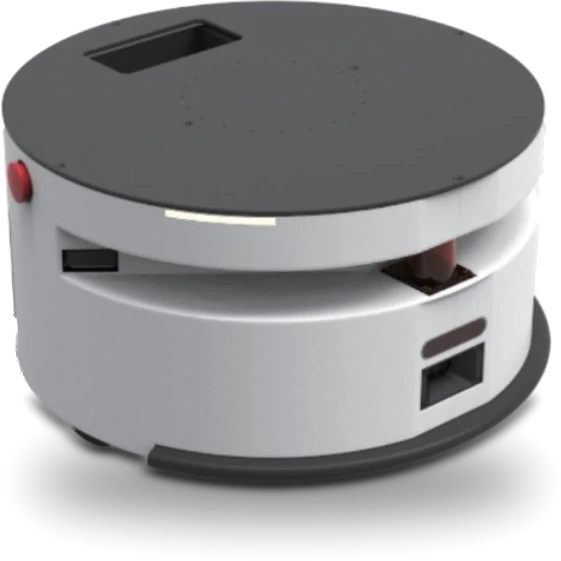
OSH60-DIFF-S
60 kg compact round differential base
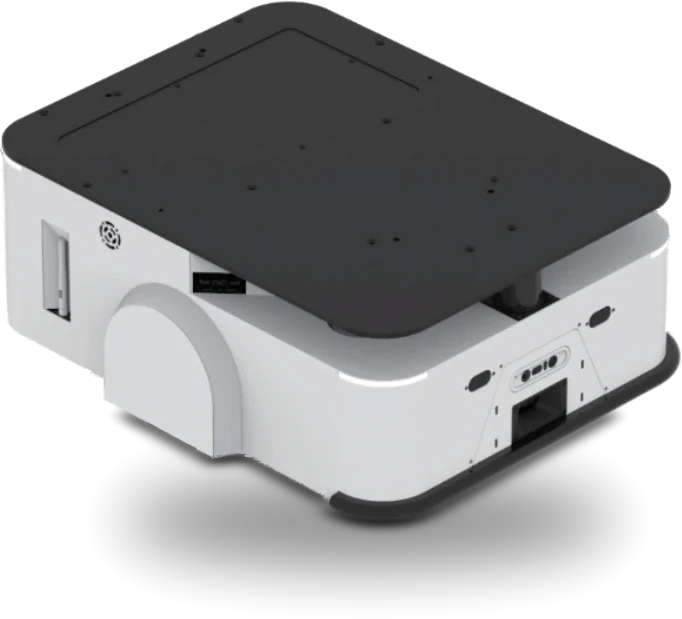
OSH80-DIFF-S
General-purpose two-wheel differential base
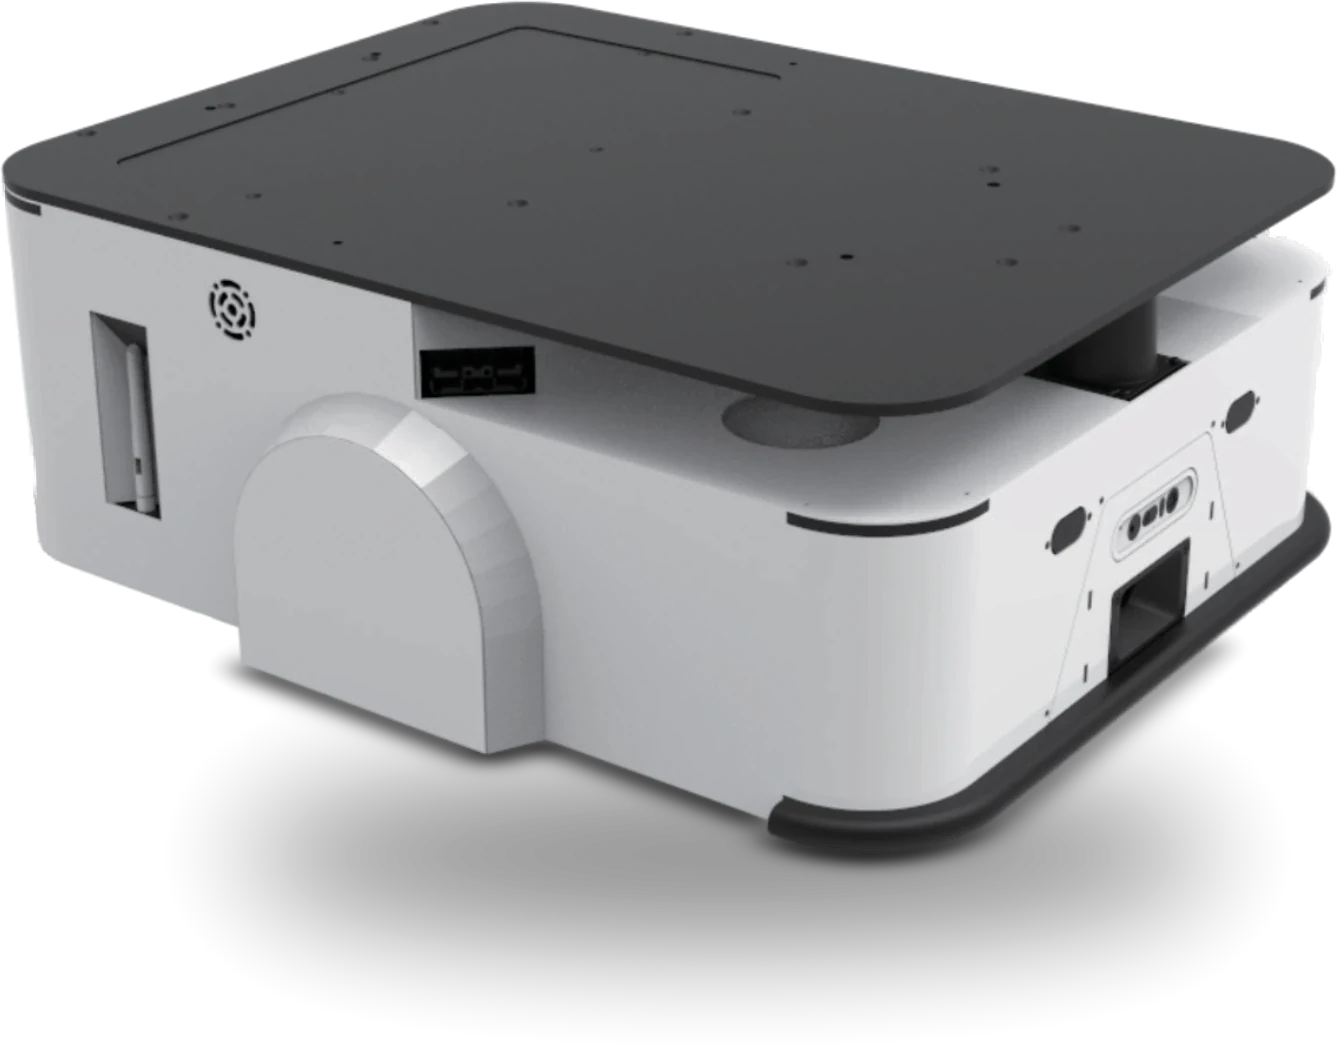
OSH100-DIFF-S
Two-wheel differential general-purpose mobile robot base
Need a custom robot built on OSH100-DIFF-S?
A solutions engineer will contact you within 1 business day with model recommendations and a quote.